7-DOF Redundant Robot Arms: Joint Selection & Kinematics for Agile Manipulation
Adding a seventh joint turns a robot from a positioner into a dexterous manipulator. How to size joints for the S-R-S 7-axis layout — and what redundancy really costs.
Incoming Inspection Guide: How to Validate Robot Joint Modules on Arrival
A test-by-test acceptance procedure for joint modules on arrival: backlash, repeatability, electrical checks, and a 48-hour burn-in.
Cleanroom Robot Joint Modules: Requirements for Semiconductor & Medical Device Automation
In an ISO Class 5 cleanroom, the robot's joints are the main particle source. Seals, lubrication, ESD — and the PP-series mapping.
Robot Joint Modules for EV Battery Manufacturing: From Cell Handling to Pack Assembly
Gigafactory robots don't all need the same joints. A station-by-station guide from cell stacking to pack assembly.
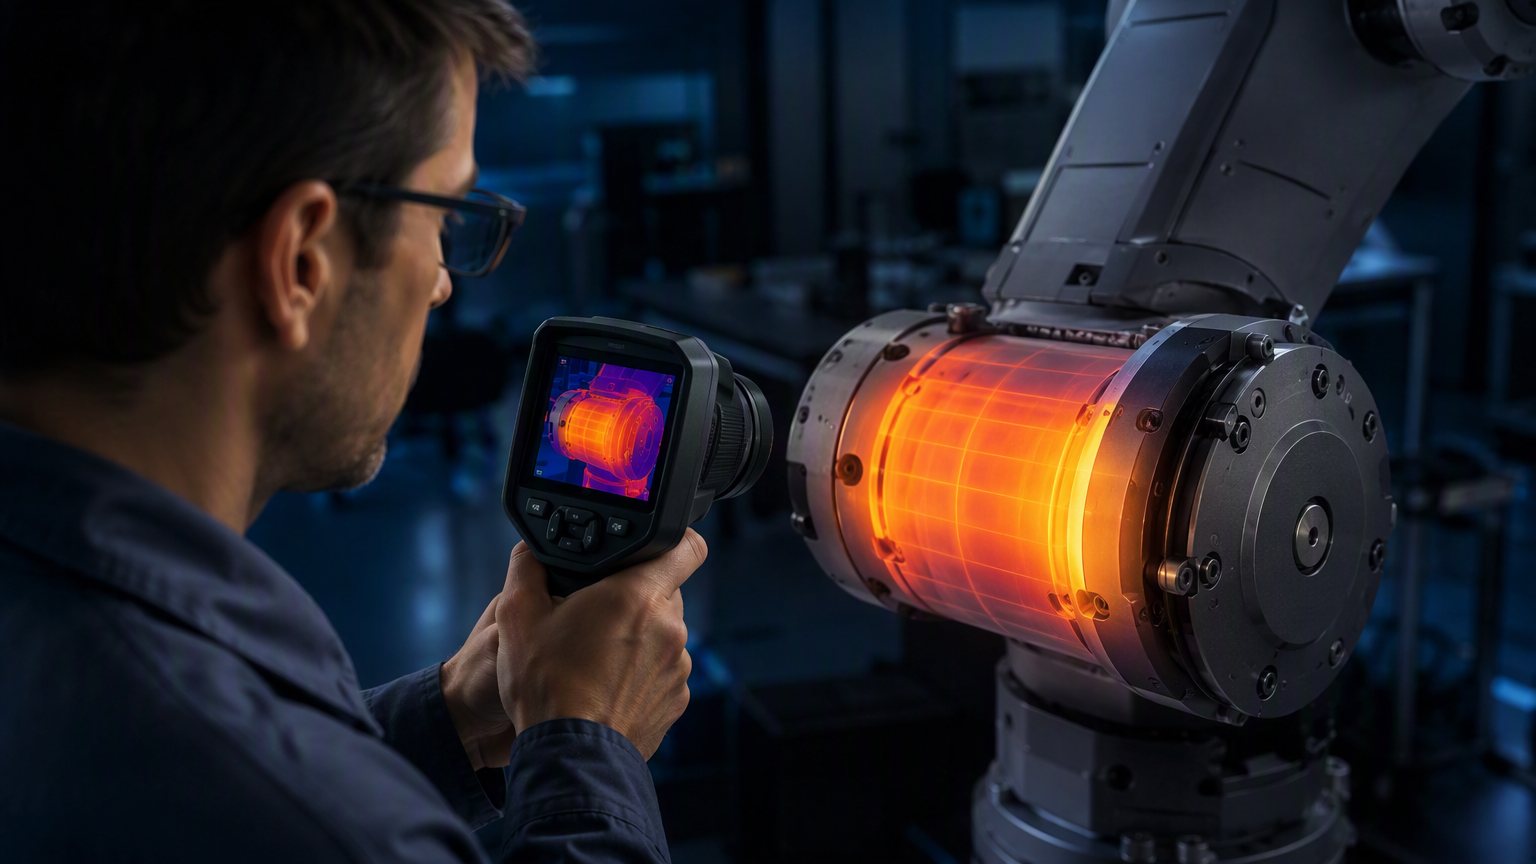
Integrated Driver Heat Dissipation: Thermal Priorities for All-in-One Robot Joint Modules
How heat flows through an integrated joint — motor, driver PCB, housing — and the design priorities that keep continuous torque up without shutdowns.
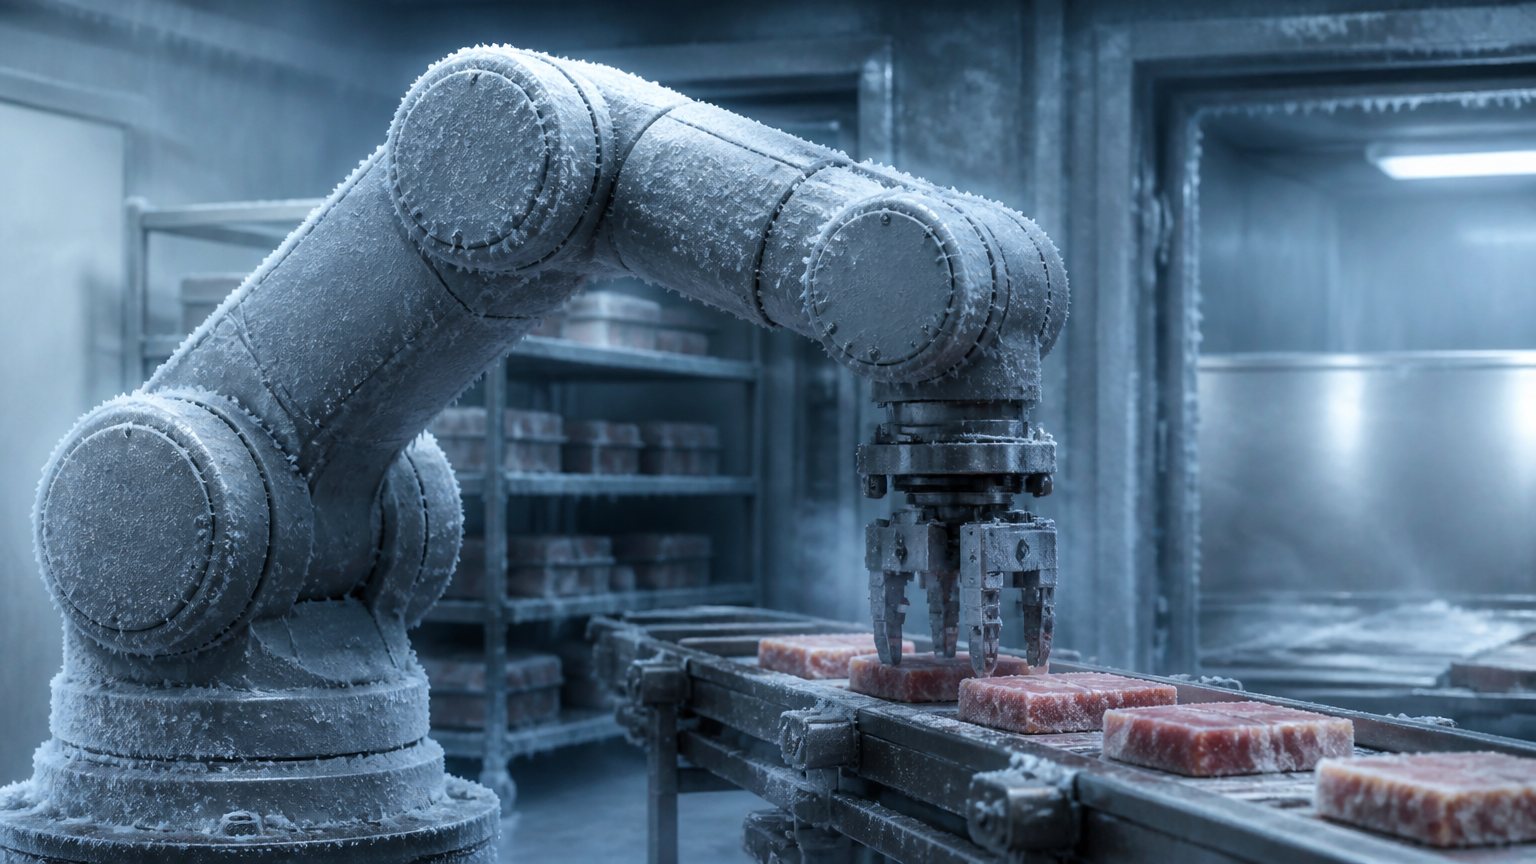
Robot Joint Module Precision in Extreme Temperatures: From -40°C Freezers to 60°C Deserts
How extreme heat and cold degrade precision — thermal expansion, grease behavior, encoder drift — and the measures that keep arms accurate.
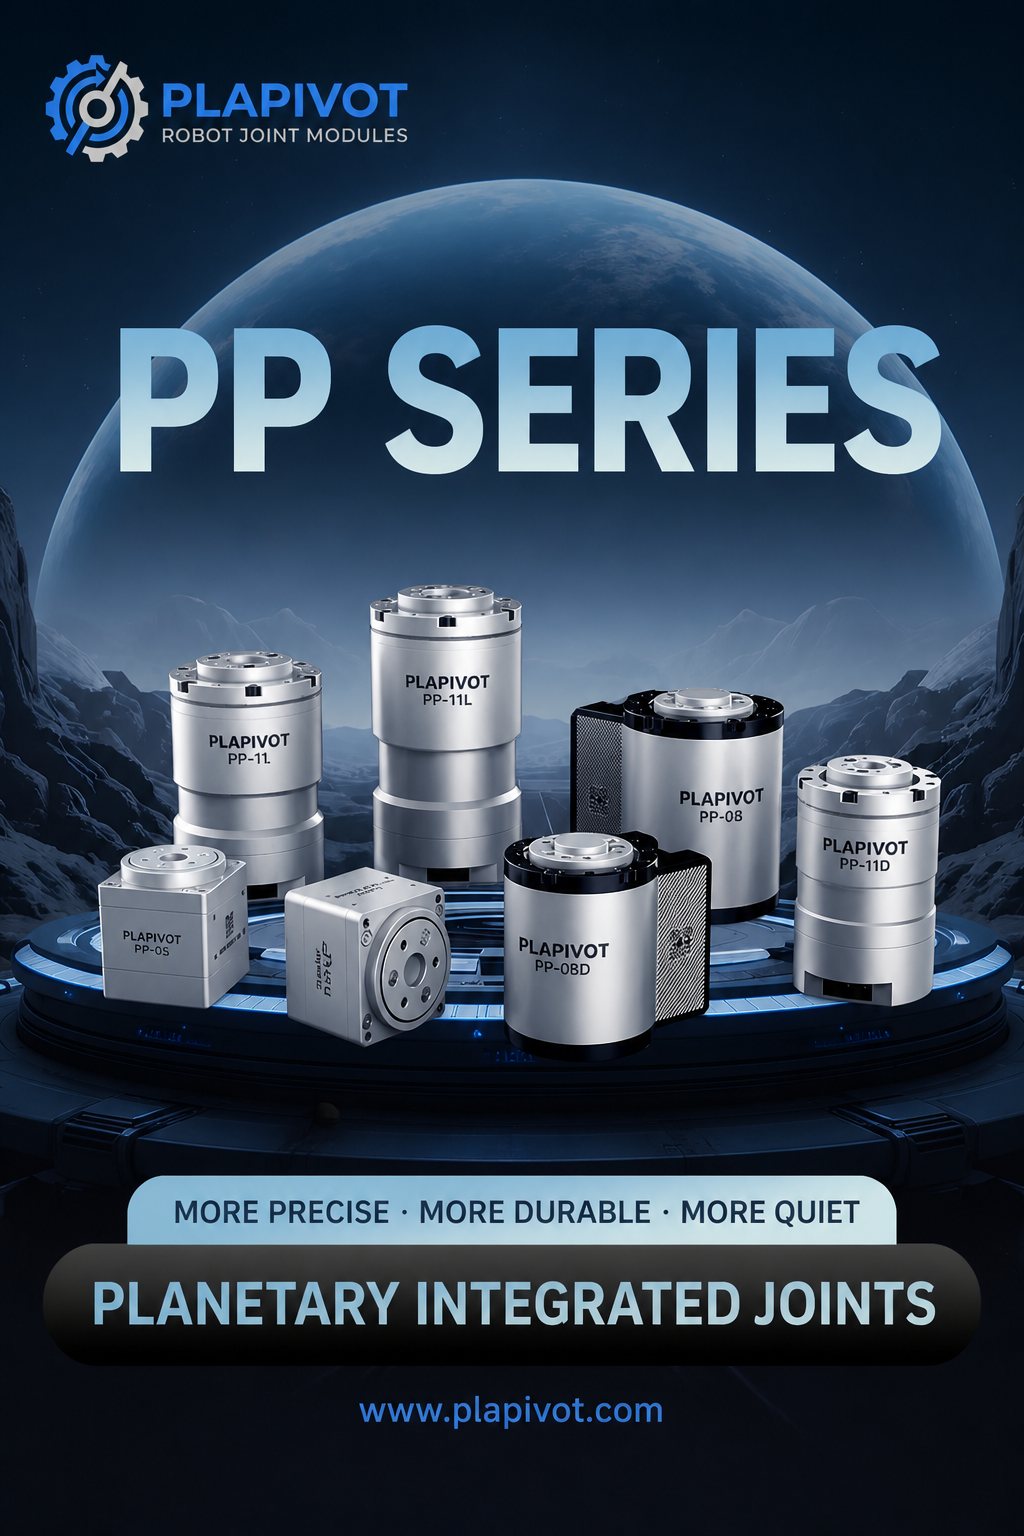
Introducing the PP Series: Compact Planetary Robot Joint Modules, 0.2 to 10 Nm
Six compact integrated joint modules with frameless torque motors, dual absolute encoders and CAN 2.0 — for humanoid robots and small robotic arms.
How to Choose Robot Joint Modules for DIY & Hobbyist Robot Arms
Beginner-friendly guide to selecting integrated actuators for your own robot build. Covers torque sizing, protocols, wiring, and PP-series BOM recommendations.
OEM Buyer's Guide to Robot Joint Modules
Comprehensive purchasing guide for OEMs: supplier evaluation, quality certifications, lead times, global logistics, and total cost of ownership.