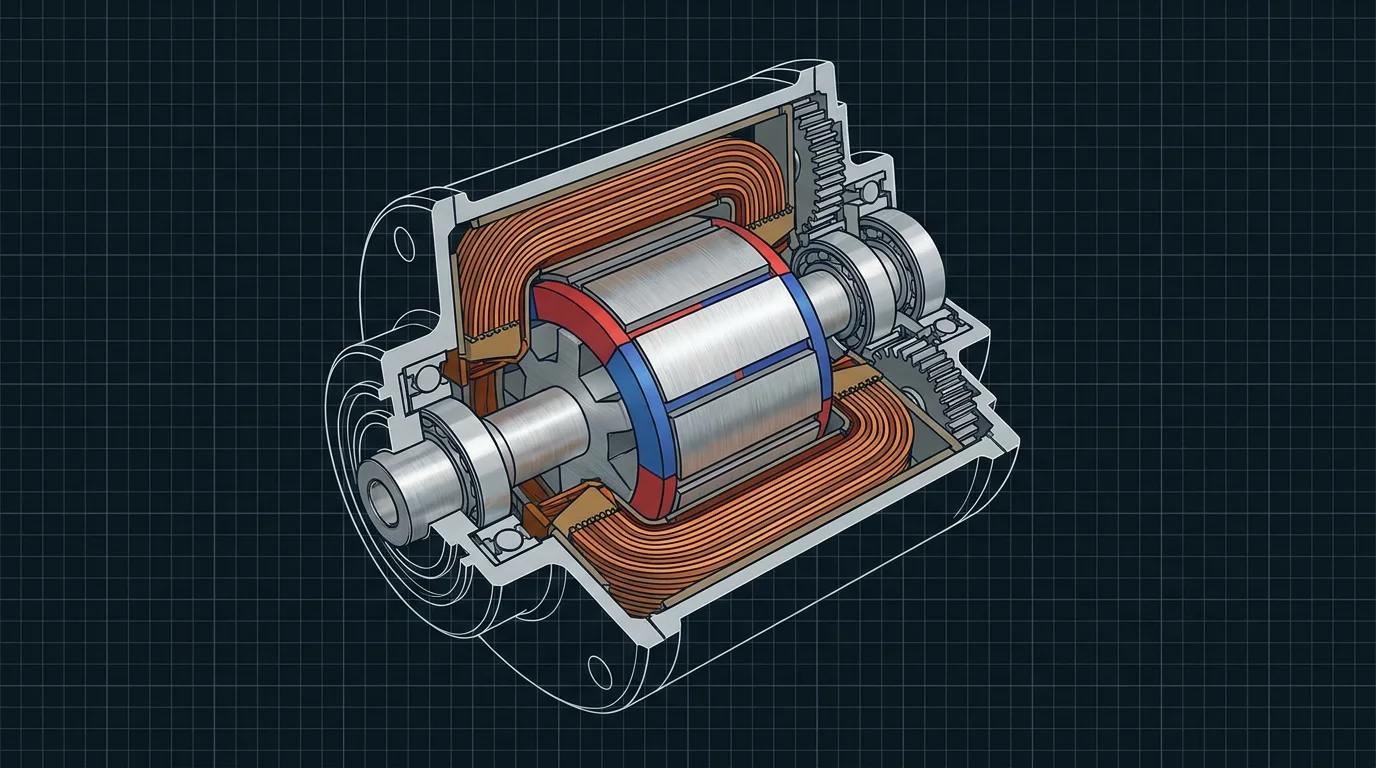
Robot Joint Module Technical Parameters Deep Dive
Understanding torque ratings, encoder resolution, backlash, repeatability, and protection ratings in joint module datasheets.
Humanoid & Exoskeleton Actuator Selection Guide
Selecting rotary and linear actuators for humanoid robots and exoskeletons: power density, walking dynamics, and joint torque profiling.
What Is a Robot Joint Module? Beginner's Guide
Complete introduction to integrated robot joint modules: what they are, how they work, key components, and why they matter for cobot design.
Small Batch Customization: Low MOQ Joint Module Guide
How to get customized robot joint modules in small quantities: customization options, lead times, and MOQ negotiation strategies.
How to Choose the Right Robot Joint Module for Your Cobot
Step-by-step guide to selecting joint modules: torque curves, encoder resolution, IP rating, and mounting considerations.
Harmonic Drive vs Planetary Gear: Reducer Comparison
In-depth comparison of strain wave gears and planetary reducers for robot joints: zero backlash, torque density, and cost trade-offs.
Integrated Joint Modules BOM Cost Breakdown
Real-world bill of materials analysis: motor, harmonic drive, encoder, driver, bearing, and housing costs broken down by tier.
The Future of Robot Joint Modules: AI-Driven Control, Digital Twins and Smart Actuators
Looking ahead at the next decade of robot joint modules, from AI-integrated control to digital twins and soft robotics.
What to Ask Your Robot Joint Module Supplier Before Placing an Order
Essential questions every engineer should ask their robot joint module supplier to ensure a successful partnership and product integration.