In 30 Seconds
Gigafactories are deploying thousands of robots across cell, module, and pack lines — and they do not all need the same joints. A high-speed cell stacking station demands light, low-inertia wrist modules with sub-arc-minute precision, while a pack palletizing cell demands 380 Nm+ heavy-duty actuators with integrated safety brakes. This guide maps the EV battery production process station by station, translates each station into concrete robot joint module requirements, and recommends a PlaPivot PP-series model for every position.
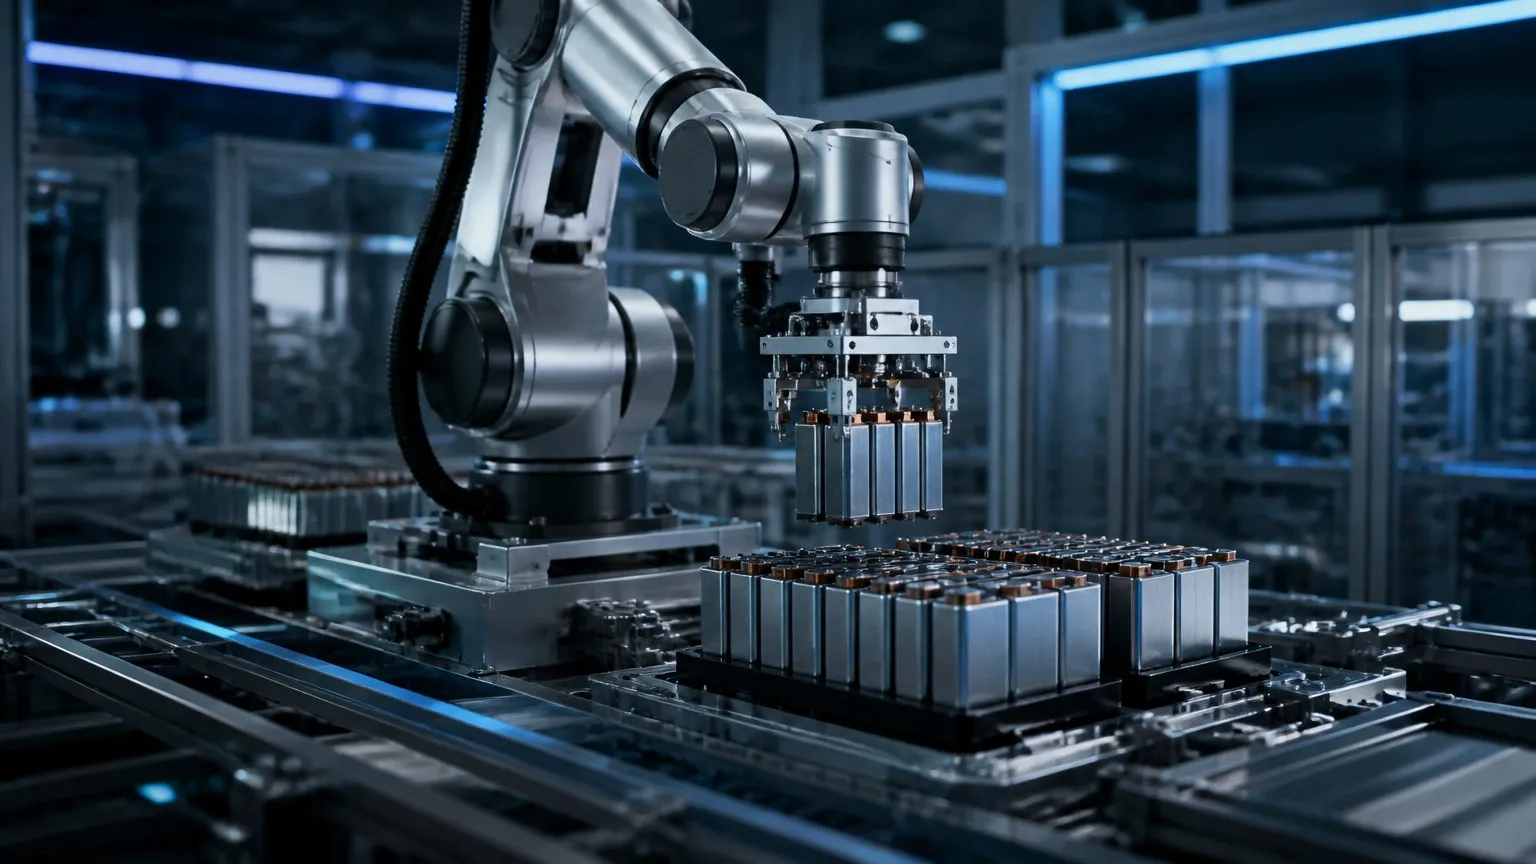
Precision cell stacking is one of the most demanding positioning tasks on a battery line.
1. The Battery Line: A Process Map
An EV battery plant is really three factories in one. Cell production turns coated electrode foils into individual cells. Module assembly groups cells into modules with busbars, thermal management, and compression frames. Pack assembly integrates modules, BMS, and high-voltage interconnect into the final battery pack. Every stage is automated, and every stage loads its robots differently:
| Stage | Typical Tasks | Load Profile |
|---|---|---|
| Cell production | Electrode winding, tab cutting, cell stacking, jelly-roll insertion | Light (0.5–3 kg), extremely fast, extremely precise |
| Module assembly | Busbar placement & welding, compression, EOL testing | Medium (5–25 kg), high stiffness, torque holding |
| Pack assembly | Tray loading, HV interconnect, sealing, pack transfer | Heavy (50–200 kg), high torque, safety-rated |
The joints that work at the wrist of a 60-picks-per-minute cell transfer robot are completely different from the joints in a pack-handling gantry. Sizing them correctly — and knowing when a catalog joint module fits instead of a custom design — is where most battery automation projects either accelerate or stall.
2. Where Precision Matters Most: Cell Stacking & Alignment
Prismatic and pouch cell stacking is the most demanding positioning task on the line. Anode, separator, and cathode layers must be stacked with alignment better than ±0.1 mm — over thousands of layers, at cycle times under two seconds. Any accumulated error, edge damage, or contamination scrapes the cell.
This is exactly the regime where harmonic drive actuators earn their place:
- Sub-arc-minute backlash means no positional dead zone when the robot reverses direction layer after layer.
- Dual absolute encoders (17-bit, motor-side + output-side) give absolute position memory — the robot resumes exactly where it stopped after a line pause, with no homing run.
- Smooth low-speed control: stacking runs at 5–20 RPM output speed, where cogging torque would create visible layer misalignment.
- Low inertia wrist joints let the arm accelerate and settle quickly without overshoot — the key to short cycle times.
For the wrist and elbow of a typical stacking robot, that means the light end of the lineup: PP-52L (0.23 kg, 2.4 Nm), PP-52 (0.5 kg, 4.8 Nm) and PP-70 (15 Nm).
3. High-Speed Pick & Place: The Wrist Joints
Cell transfer robots move at 60–80 picks per minute. The physics of fast pick-and-place are unforgiving: wrist mass multiplies through the arm, so every 100 g saved on the wrist cuts the required shoulder torque and the settling time. Two PP-series details matter here:
- The hollow shaft (∅8 mm on PP-52L/PP-52) routes cables and vacuum lines for the gripper through the joint axis — no external tubing to snag or drag.
- The integrated servo driver eliminates a separate drive cabinet and keeps cable capacitance short, which matters at high commutation frequencies.
If you are new to sizing these stations, our torque calculation guide walks through static load, dynamic inertia, and the 20–30% headroom rule in detail.
4. Welding & Module Assembly: Stiffness and Torque Holding
Busbar laser welding and module compression are the opposite regime: the robot must hold a pose under load while a weld or press completes. What matters is no longer speed — it is torsional stiffness, low backlash, and torque holding:
- Sub-arc-minute backlash (below 1 arcmin, and below 0.5 arcmin on the larger PP-90 and up) keeps the weld seam consistent when the joint direction reverses.
- Peak torque capacity: busbar placement can see momentary reaction spikes 2–3× the steady load. PP-80 (35 Nm rated / 70 Nm peak) and PP-90 (60 Nm rated / 120 Nm peak) absorb these without tripping the driver.
- Integrated safety brake on PP-90 and up holds the arm in position during an E-stop — critical on a line where a dropping module is a safety incident, not a quality issue.
5. Heavy Payload: Pack Assembly
Pack assembly robots handle 50–200 kg of modules and trays at the end of the line. The PP-170 (380 Nm rated / 840 Nm peak) and PP-170P (420 Nm rated / 950 Nm peak) cover this class with integrated brakes as standard. For stations near cell electrolyte handling or washdown areas, the PP-170P's IP65 sealing adds protection against splash and mist.
6. Environment: ESD, Voltage and Cleanliness
Battery lines add constraints beyond torque:
- 48 V DC — the entire PP-series runs on a single 48 V bus, simplifying line power distribution.
- EtherCAT — deterministic cycle-synchronized control across dozens of axes is the norm in gigafactories; all PP-series models support EtherCAT and CANopen natively.
- Cleanliness — sealed housings and internal harmonic drive lubrication keep grease and wear particles inside the joint, which matters in the dry-room cell section.
- Operating range −20 °C to +40 °C covers dry rooms and non-climate-controlled assembly halls.
7. Worked Example: A Prismatic Cell Stacking Robot
Take a 6-axis stacking robot, 1.0 m reach, 5 kg end-of-arm tooling plus a 2 kg cell payload. Using static + dynamic torque analysis with 20–30% headroom, a representative joint map looks like this:
| Joint | Calc. Peak (Nm) | Recommended Module | Headroom |
|---|---|---|---|
| J1 (Base) | 45 | PP-90 (60 Nm) | 33% |
| J2 (Shoulder) | 42 | PP-90 (60 Nm) | 43% |
| J3 (Elbow) | 25 | PP-80 (35 Nm) | 40% |
| J4 (Wrist pitch) | 11 | PP-70 (15 Nm) | 36% |
| J5 (Wrist yaw) | 8 | PP-70 (15 Nm) | 88% |
| J6 (Wrist roll) | 3.8 | PP-52 (4.8 Nm) | 26% |
Every module ships with a dyno test report, and the dual-encoder feedback means each joint reports its true output position back to the line controller — useful data for your MES and quality traceability.
8. Next Steps
Battery automation rewards standardized, factory-tested joints: predictable torque curves, documented backlash, and a single supplier to hold accountable across 30+ axes of a line. The PP-series spans 2.4 to 420 Nm precisely because a cell line and a pack line are different machines.
Related reading: How to Choose the Right Robot Joint Module for Your Cobot and Robot Joint Module Cost Breakdown.
Planning a Battery Automation Line?
Tell us about your application — cell format, cycle time, and payload. Our engineering team will respond with a tailored joint map and quotation within 24 hours.
Request Quote & Datasheet