In 30 Seconds
As embodied AI and humanoid manipulation advance into unstructured physical environments in 2026, pure kinematic positioning is no longer sufficient. Robots require real-time dynamic compliance and sensitive contact force perception. While older designs attempted to estimate joint force using motor field-oriented current (Iq), gearbox friction, temperature drift, and elasticity introduce up to 20% measurement error. This technical guide explores why six-in-one joint modules with dedicated output torque sensors have become essential for modern force control.
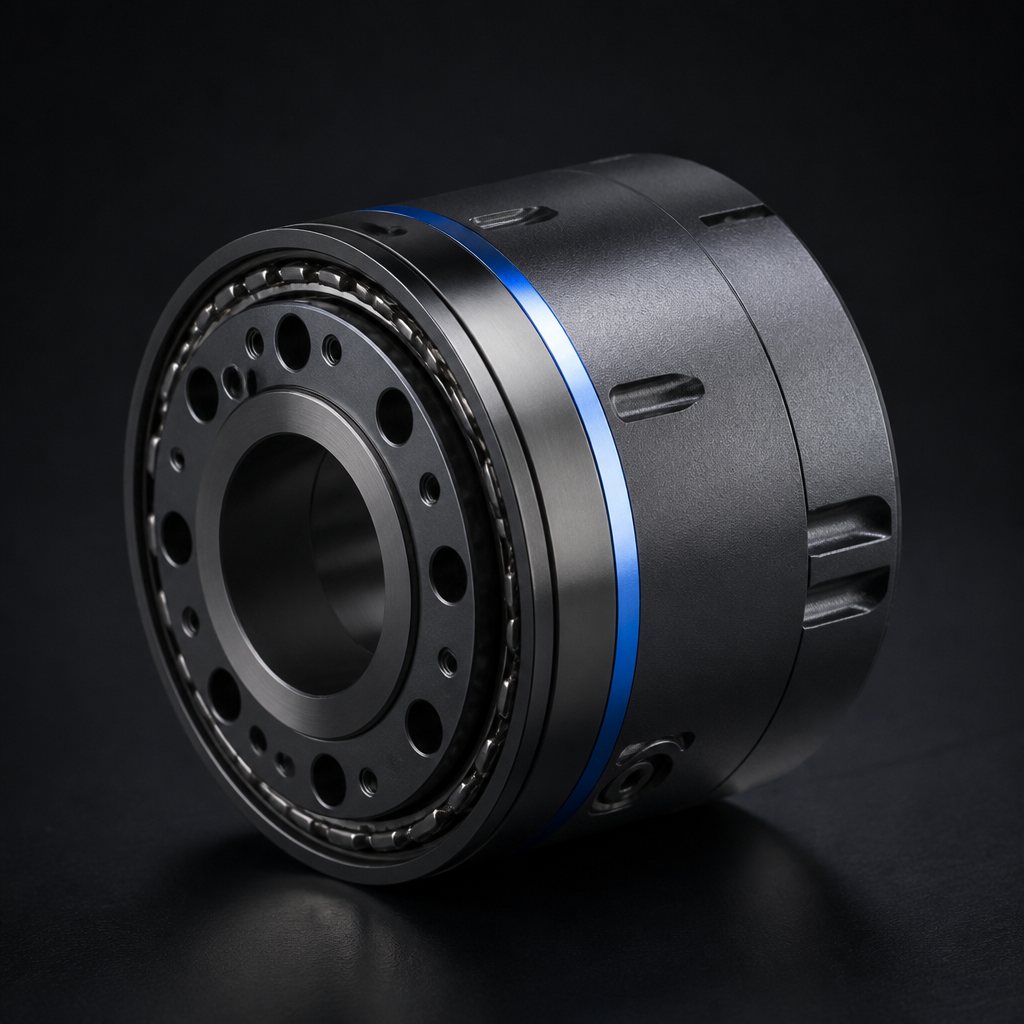
PlaPivot PRO series embeds a spoke-type strain-gauge torque sensor directly at the joint output flange.
1. The Fatal Flaw of Motor-Current Torque Estimation
In traditional servo motor systems, engineers frequently rely on the formula: τ = K_t × I_q × N (where K_t is the torque constant, I_q is quadrature current, and N is gear ratio). While mathematically simple, placing a high-ratio reducer (e.g., 50:1 to 120:1 harmonic drive) between the motor and the joint output breaks this linear assumption:
- Non-Linear Gearbox Friction: Harmonic drives exhibit significant static friction (Stribeck effect) and viscous friction that varies with input velocity and lubricant temperature.
- Hysteresis and Torsional Compliance: The thin-walled flexspline flexes elastically under load, storing and releasing mechanical energy that is completely invisible to motor-side current measurement.
- Temperature Sensitivity: As internal module temperature rises from 25°C to 65°C during heavy duty cycles, grease viscosity changes by over 40%, shifting the apparent torque baseline.
In physical tests, current-based force estimation exhibits a typical error margin of ±12% to ±20% of rated torque—far too coarse for delicate robotic assembly, collaborative safety limits, or walking balance stabilization.
2. How Six-in-One Joint Modules Solve the Compliance Challenge
To achieve high-fidelity force control without external sensor harnesses, next-generation actuators integrate all six critical electromechanical subsystems into a single compact casing:
| Subsystem | Standard Function | PRO Six-in-One Implementation |
|---|---|---|
| 1. Frameless Motor | High-torque BLDC rotor/stator | Optimized slot-pole ratio for minimal cogging torque |
| 2. Harmonic Reducer | Speed reduction & torque multiplication | Zero-backlash cup/hat type flexspline (<1 arcmin) |
| 3. Integrated Driver | Field-Oriented Control (FOC) | FOC velocity, position, and torque inner loop (20 kHz) |
| 4. Dual Absolute Encoders | Motor commutation + output feedback | 17-bit multi-turn motor side + 17-bit output absolute encoder |
| 5. Joint Torque Sensor | Output load force measurement | Direct output strain-gauge bridge with 12-bit ADC filtering |
| 6. Safety Brake | Power-off static holding | Spring-loaded electromagnetic safety brake option |
3. Performance Comparison: Current Estimation vs. PRO Torque Sensor
The difference between indirect estimation and direct output measurement is dramatic in closed-loop impedance control:
| Parameter | Motor Current Estimation (Iq) | PlaPivot PRO Integrated Torque Sensor |
|---|---|---|
| Torque Measurement Accuracy | ±15% ~ ±20% of rated torque | ±1.0% ~ ±1.5% Full Scale |
| Minimum Detectable Contact Force | 3.5 ~ 6.0 Nm (blind zone) | 0.15 ~ 0.35 Nm (ultra-sensitive) |
| Control Loop Bandwidth | < 50 Hz (filtered to suppress noise) | Up to 500 Hz high-speed torque loop |
| Lead-Through Manual Teaching | Heavy, stiff, noticeable resistance | Zero-gravity virtual floating feel |
| Collision Reaction Time | 45–80 ms | < 5 ms immediate compliant yield |
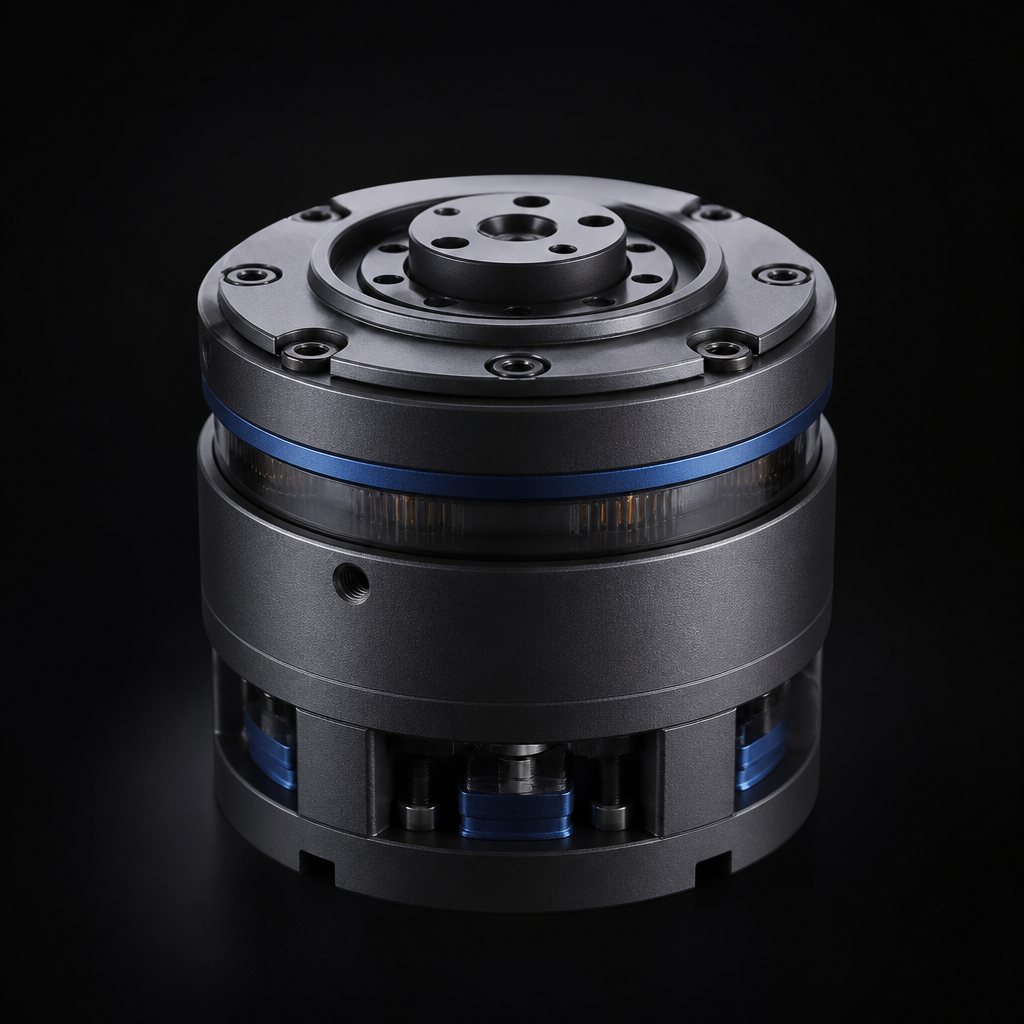
Compact 60mm diameter PRO joint delivers 18 Nm rated torque and high-speed torque feedback for robotic arms and humanoid limbs.
4. The PlaPivot PRO Series Lineup
PlaPivot manufactures three standardized PRO series joint modules designed specifically for force-controlled robotics:
- PP-60-PRO (18 Nm Rated Torque): Weighing just 392g with an outer diameter of Φ60mm, ideal for cobot wrists, medical rehabilitation devices, and lightweight service arms.
- PP-70-PRO (51 Nm Rated Torque): Φ70mm profile, 812g mass. Optimized for humanoid elbow and shoulder axes requiring rapid dynamic compliance.
- PP-80-PRO (64 Nm Rated Torque): Φ80mm profile, 1159g mass. High-rigidity construction for humanoid torso/waist and industrial cobot primary axes.
5. Summary
For research and commercial robotics in 2026, shifting from motor-current force estimation to integrated six-in-one joint modules is the single most effective upgrade for achieving robust Physical AI manipulation and ISO/TS 15066 collaborative safety compliance.
Upgrading to Force-Controlled Joint Modules?
Evaluate PlaPivot's PRO series actuators. All models feature built-in torque sensors, dual absolute encoders, EtherCAT/CAN interfaces, and single-unit prototype availability.
Request PRO Datasheet & Quote