In 30 Seconds
A joint module's datasheet precision — sub-arc-minute backlash, ±0.003° repeatability — is true at about 20 °C. In a −25 °C cold-storage line or a 55 °C desert plant, the physics change: grease thickens, metals shrink or swell, and the arm itself expands far more than the joint's own error budget. This guide quantifies those effects and lays out the operational measures — warm-up, derating, compensation — that keep robot joint module precision intact at the extremes.
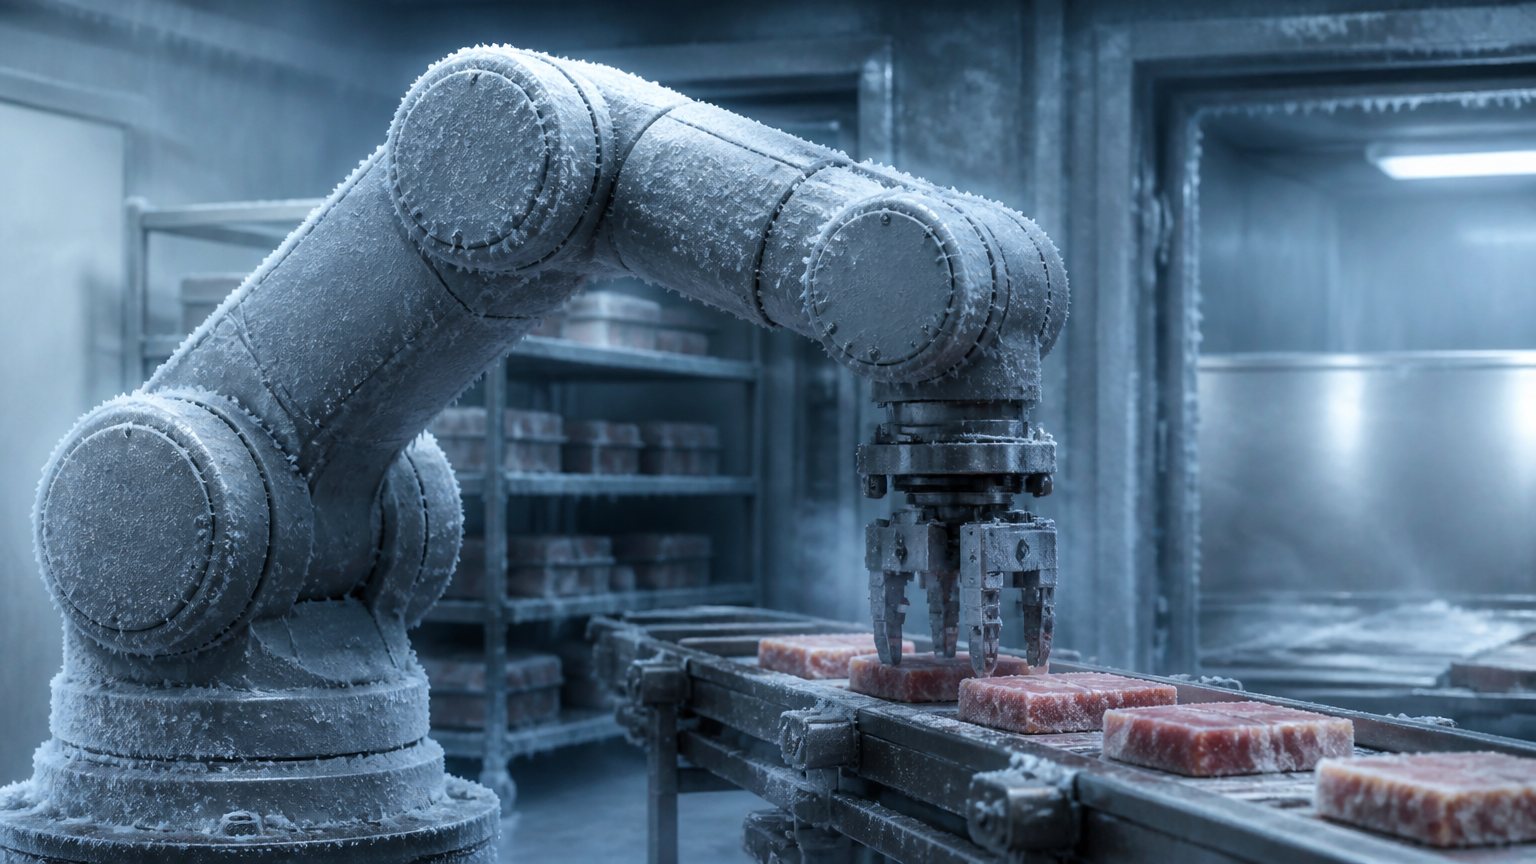
Cold-storage automation pushes joint modules to the edge of their thermal envelope.
1. Where Do Temperature Errors Come From?
Four physical effects degrade precision as temperature moves away from the nominal 20 °C:
| Effect | Cold side (−40 °C…0 °C) | Hot side (+40 °C…+60 °C) |
|---|---|---|
| Thermal expansion / contraction | Housing and links shrink; bearing clearances tighten | Links grow; clearances open; alignment drifts |
| Lubricant behavior | Grease thickens, friction and stall torque rise | Grease thins, film strength drops, life shortens |
| Motor & electronics | Reduced risk; condensation/frost on encoders is the danger | Winding temperature rises toward demagnetization; driver derates |
| Encoder & feedback | Thermal contraction of scale/disk can shift zero | Thermal drift of electronics, expansion of code disk |
The dominant error in a real robot is almost never the joint's internal backlash — it is thermal expansion of the arm links. A 1 m aluminum arm experiencing a 30 °C swing grows by roughly 0.7 mm at the tool (aluminum expands ~23 ppm/°C). Compare that with a joint repeatability of ±0.003° at a 400 mm radius (≈±0.02 mm) and you see the ratio: the environment, not the joint, sets the accuracy budget in extreme temperatures.
2. What Is the Real Operating Envelope?
PP-series modules are rated for −20 °C to +40 °C ambient operation. Two clarifications that matter in practice:
- −20 °C is a conservative, whole-module rating (electronics + grease + seals). It covers most cold-storage lines (−18 °C to −25 °C) with warm-up discipline. Below that, custom low-temperature grease and connector options are needed — a factory conversation, not a datasheet checkmark.
- +40 °C is an ambient ceiling, not a hard stop. Above it the module still runs, but the continuous-torque envelope derates because the housing cannot shed motor and driver heat fast enough. The hotter the cell, the more duty-cycle margin you must design in.
For the sealing side of hot, dusty environments, see our tropical climate guide; the two problems often arrive together in outdoor plants.
3. Cold Environments: Freezer Lines and Arctic Outdoor Duty
Cold-storage robots (−18 °C to −25 °C) and outdoor installations are the two big cold-side applications. The failure sequence is predictable:
- Startup stall: viscous grease raises breakaway torque; a controller expecting 20 °C behavior may trip on over-current. Solution: powered warm-up — run each joint at low speed/velocity-limited mode for 2–5 minutes before full operation.
- Frost and condensation: moving a cold arm into a humid zone condenses water on seals and connectors. Keep modules powered (internal warmth above dew point) and seal cable entries.
- Contraction and preload: thermal contraction changes bearing preload; expect slightly stiffer motion and reduced backlash margin until temperature stabilizes.
Cold-side rule of thumb: plan for a warm-up cycle in the production schedule, and never spec a cold-line joint with zero thermal headroom — a 15 Nm module running at 14 Nm continuous in a freezer will behave very differently from the same module at 20 °C.
4. Hot Environments: Desert Plants and Process Heat
On the hot side the enemy is accumulated heat: motor copper loss (I²R) plus driver losses heat the sealed housing, and the ambient starts closer to the ceiling already.
- Torque derating: continuous torque is the number that shrinks, not peak torque. Design with 30%+ headroom when ambient exceeds 40 °C.
- Motor protection: winding temperature is the hard limit — sustained overload risks magnet demagnetization, a permanent torque loss that datasheets do not come back from.
- Driver protection: integrated drivers carry on-board temperature sensing and current limiting; they derate gracefully rather than failing — but only if the system software honors the protection signals.
- External airflow: fans or a ventilated cell dramatically extend the continuous-torque envelope of a sealed module — the single cheapest hot-side fix.
The driver's thermal priorities are covered in depth in our companion guide: Integrated Driver Heat Dissipation.
5. Compensation Strategies for Sub-Millimeter Work
When the task demands precision despite a temperature swing, work at the system level:
| Strategy | Effort | Effectiveness |
|---|---|---|
| Climate-controlled cell (AC / insulation) | Medium capex | Removes the problem entirely |
| Temperature compensation in software | Engineering time | Good for link expansion if temperature is measured |
| Dual absolute encoders + calibration at operating temp | Low | Recovers joint-level truth; does not fix link growth |
| Duty derating (hot) / warm-up (cold) | Low | Prevents damage; restores normal behavior |
For most cold-storage and outdoor applications, warm-up + derating + dual-encoder calibration at the operating temperature is sufficient. Sub-millimeter positioning across a wide temperature swing without compensation is a physics problem, not a component problem.
6. Specification Checklist for Extreme Environments
- ☐ Confirm the module's ambient operating range covers your worst case (−20 °C to +40 °C standard; factory options beyond)
- ☐ Plan a powered warm-up cycle for cold lines; document it in the cell PLC logic
- ☐ Size continuous torque with 30% headroom if ambient exceeds 40 °C
- ☐ Provide external airflow in hot cells; protect cable entries from condensation in cold/humid zones
- ☐ Calibrate the arm at the operating temperature, not at the lab temperature
Deploying a Joint Module in Extreme Temperatures?
Tell us your environment — coldest and hottest ambient, humidity, duty cycle — and our engineering team will confirm suitability and derating within 24 hours.
Request Quote & Datasheet