The electronics industry moves faster than any other. In a world of shrinking components and increasing throughput, the robot joints used in SMT (Surface Mount Technology) and PCB assembly must deliver incredible speed without sacrificing a single micron of precision. Here's how high-performance actuators are keeping the digital world moving.
The Need for Speed: High-Cycle Assembly
In a typical PCB assembly line, a robot might perform thousands of pick-and-place operations per hour. This requires joint modules with very low inertia and high acceleration capabilities. We use lightweight aluminum and titanium components in the motor rotors and gear housings to minimize moving mass, allowing for the rapid 'start-stop' motion profiles that define high-speed electronics manufacturing.
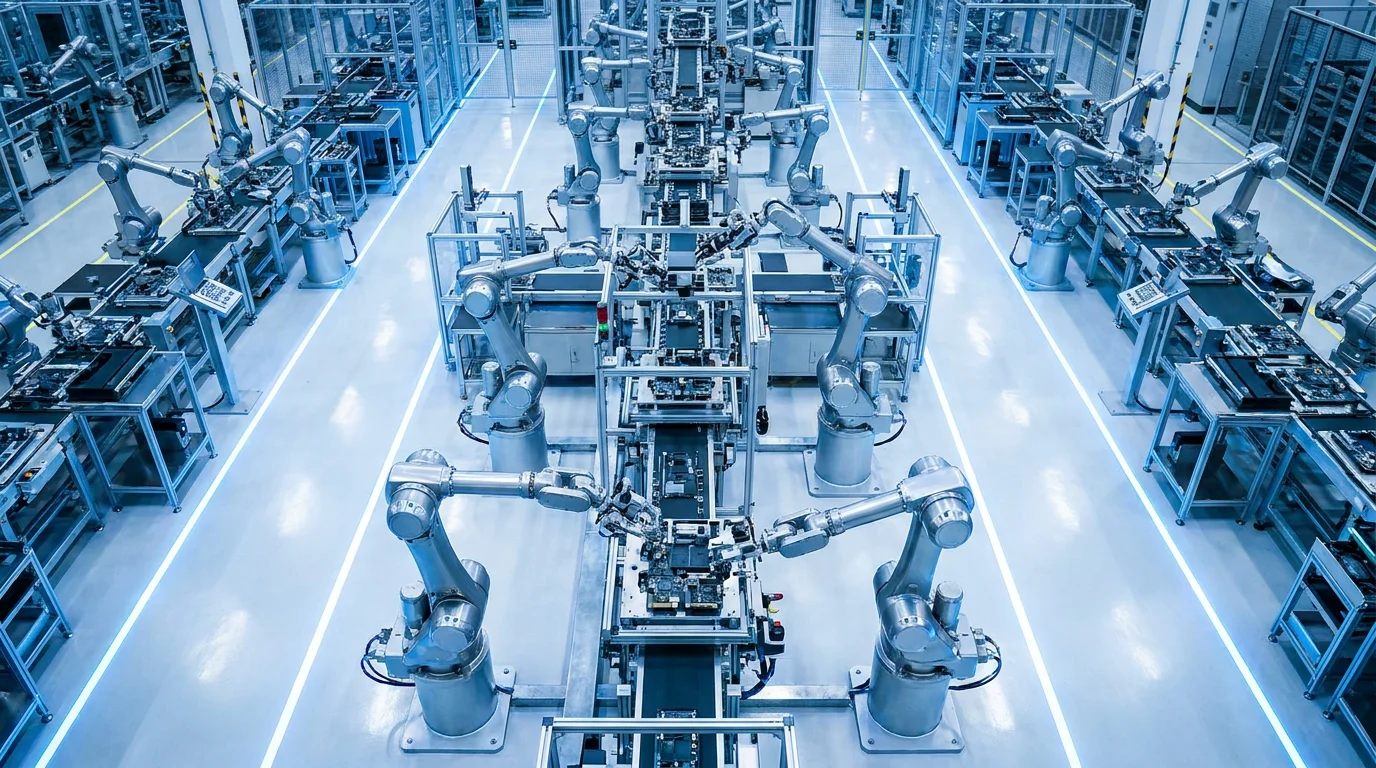
Technical illustration for High-Speed Robot Joint Modules for Electronics Assembly and PCB Handling.
Micron-Level Precision for Micro-Electronics
As components like 01005 resistors become standard, the margin for error disappears. A placement error of 20 microns can lead to a failed board. Our joint modules use 17-bit dual absolute encoders and precision-ground harmonic drives to achieve the repeatability needed for these tasks. Advanced calibration techniques, including laser interferometry, are used during manufacturing to map and compensate for any infinitesimal non-linearities in the gear movement.
Cleanroom Compatibility and Low Outgassing
Electronics manufacturing often takes place in ISO Class 5 or Class 6 cleanrooms. Joint modules must not contaminate the environment. We use vacuum-rated lubricants and specialized seals to prevent any particle shedding. Furthermore, we select materials with low outgassing properties to ensure that no chemical vapors settle on sensitive semiconductor wafers or optical components during the assembly process.
Technical illustration for High-Speed Robot Joint Modules for Electronics Assembly and PCB Handling.
ESD Protection and Static Dissipation
Electrostatic discharge (ESD) can instantly destroy a sensitive integrated circuit. Robot joints must be integrated into the factory's ESD grounding scheme. We ensure that there is a low-resistance path from the end-effector through the joints to the robot base. Conductive lubricants and specialized grounding brushes are often used within the joint to ensure that static doesn't build up on the rotating parts of the actuator.
Modular Integration for Customized Lines
Electronics lines are constantly being reconfigured for new products. The standardized, all-in-one design of our joint modules allows machine builders to quickly assemble custom 4-axis or 6-axis configurations. With support for high-speed industrial Ethernet protocols like EtherCAT, these modules can be daisy-chained together, reducing wiring complexity and allowing for rapid deployment of new assembly cells.
Thermal Management in High-Cycle SMT Cells
Every pick-and-place cycle dumps heat into the motor and the integrated driver, and it accumulates faster than in a factory arm — cycle times of 0.5–1.0 s are normal. Continuous torque ratings assume a stated ambient temperature and duty cycle, so the joint map must keep steady-state loads inside the continuous envelope with 20–30% headroom; peak torque (roughly 2× continuous on the harmonic series) is reserved for acceleration spikes. On a 48 V DC bus, the wrist joints (PP-08, 4.5 Nm) rarely thermal-limit, but a base joint swinging a full arm will. Stream winding temperature from the EtherCAT/CAN FD telemetry registers and set soft thermal limits in the motion controller — a temporary speed reduction beats a hard shutdown in the middle of a run.
A Compact 4-Axis Joint Map: Worked Example
For a PCB cell with a 0.5 m reach and 1.5 kg payload, a light four-joint map keeps acceleration high because the motors spend most of their torque moving the arm itself:
| Joint | Model | Continuous torque | Weight |
|---|---|---|---|
| Base | PP-14 | 36 Nm | 0.7 kg |
| Shoulder | PP-11 | 10.5 Nm | 0.37 kg |
| Elbow | PP-08 | 4.5 Nm | 0.16 kg |
| Wrist | PP-08 | 4.5 Nm | 0.16 kg |
The full joint stack weighs only ~1.4 kg, so a 1.5 kg payload dominates the load torque and the base joint holds the 36 Nm rating with headroom for a 0.4 g tool-point acceleration. Every model carries the 17-bit dual absolute encoders, so the arm powers up at the correct pose — critical when a line restart must not re-run a homing move across a populated board.
Incoming Inspection and Line Commissioning
Before a new joint goes onto a live SMT line, spend ten minutes verifying what the supplier shipped: the per-serial test report (measured torque, no-load current and backlash at 48 V DC), the firmware version locked for your build, and a loop-back test on the EtherCAT ring to confirm the telemetry registers are readable. With no MOQ on standard models, a 12-month warranty and engineering response within 24 hours, a spare PP-08 or PP-11 on the shelf is cheap insurance against a line stop — and because every module is a sealed, integrated unit, a failed joint is swapped in minutes, not repaired in place.
Ready to start your build?
Our engineering team is ready to help you select the perfect robot joint modules for your application. Get expert advice and a custom quotation within 24 hours.
Get a Quote & DatasheetRelated articles you might find useful: