Size matters in robotics, but bigger isn't always better. The challenge for any robot designer is finding the 'Goldilocks' joint—one that is small enough to keep the arm lightweight but powerful enough to handle the payload. At PlaPivot, we offer a range of modules from 52mm to 170mm in diameter. This guide compares our most popular sizes to help you find the right fit for your build.
1. The Compact Class: 52mm to 65mm (PP-65)
These are our smallest modules, designed for 'lightweight' tasks. With a diameter similar to a soda can, the PP-65 is the go-to choice for the wrists of 6-axis cobots, small desktop arms, and laboratory liquid handlers. Despite its small size, it can deliver up to 10Nm of peak torque. Because it weighs only 500-700 grams, it allows for high-speed 'flick' movements that larger joints simply can't match. If your robot's total reach is under 500mm and your payload is under 2kg, this class provides the best balance of agility and strength. Their compact form factor also makes them ideal for integrated camera gimbals and stabilized platforms where space is at a premium.
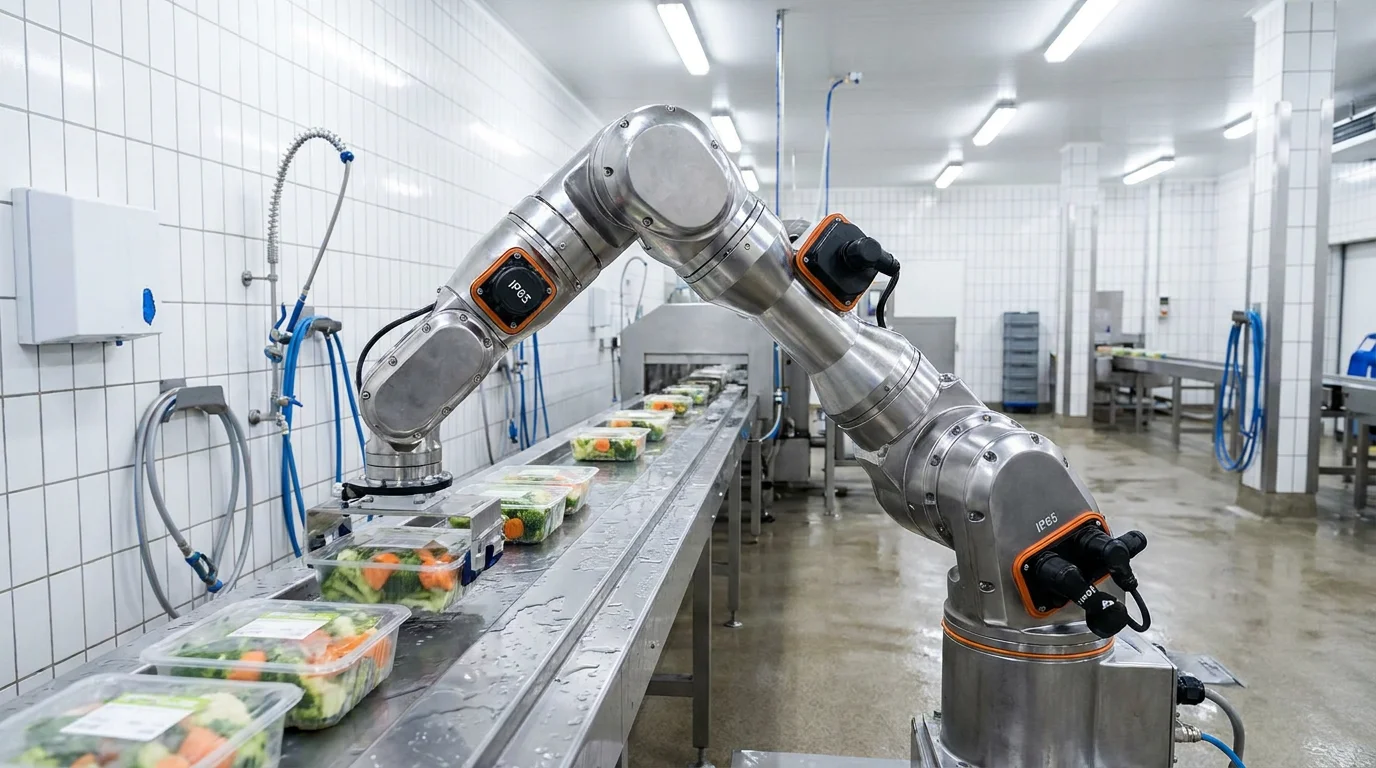
Figure: Technical implementation of Robot Joint Module Size Comparison: 52mm to 170mm Diameter Shootout. High-precision components for reliable robotic motion.
2. The Mid-Range Workhorses: 80mm to 100mm (PP-80/PP-100)
This is the 'sweet spot' for most industrial and collaborative robots. An 80mm module (like the PP-80) typically produces 30-40Nm of torque, making it ideal for the 'elbow' (J3) of a 5kg-payload arm or the 'shoulder' of a smaller 3kg arm. The 100mm modules (PP-100) jump up to 60-80Nm. These sizes almost always feature a 'hollow shaft' design, allowing for internal cable routing. They are robust enough for machine tending and palletizing but small enough to maintain a sleek, human-friendly profile. This range offers the best compromise between torque capability and mechanical flexibility, supporting most modern manufacturing automation needs.
3. The Heavy-Duty Series: 120mm to 170mm (PP-120/PP-170)
When you need to move heavy loads—10kg, 20kg, or more—you need the 120mm and 170mm classes. These modules are significantly larger and heavier, but they provide the massive torque (up to 200Nm+) required for the base (J1) and shoulder (J2) of full-scale industrial robots. They feature massive cross-roller bearings that can support hundreds of kilograms of radial force without deflection. While they aren't as 'agile' as a 65mm module, they provide the rock-solid stability needed for heavy-duty welding, large-scale 3D printing, and automotive assembly. These units are built for high-duty cycles and extreme environments where physical durability is the top priority.
Figure: Technical implementation of Robot Joint Module Size Comparison: 52mm to 170mm Diameter Shootout. High-precision components for reliable robotic motion.
4. Hollow-Shaft vs. Standard: Why Diameter Matters
As the diameter of a joint module increases, so does the size of its internal aperture. A 110mm module like the PP-110 offers a massive hollow shaft that can accommodate not just power and data cables, but also pneumatic lines and vacuum tubes. This internal routing is essential for 'clean' robot designs where external wires would snag or fail. Larger diameters also allow for larger-diameter bearings, which exponentially increases the joint's 'moment' capacity. This means a larger module can support a much longer lever arm without the gearbox teeth being pulled out of alignment. Choosing a larger diameter isn't just about more torque; it's often about better mechanical integration.
5. Tapered Design: Optimizing Your Arm's Kinematics
To simplify your selection, consider these benchmarks: The PP-65 (65mm) offers 6Nm continuous / 15Nm peak; The PP-80 (80mm) offers 18Nm continuous / 45Nm peak; The PP-110 (110mm) offers 45Nm continuous / 120Nm peak. Note that as the diameter increases, the maximum speed (RPM) typically decreases due to the higher gear ratios needed to generate that torque. When designing your arm, we recommend 'tapering' the sizes: use a 110mm at the base, 80mm at the elbow, and 65mm at the wrist. This mimics human anatomy, keeping the heaviest motors close to the body and the lightest at the extremities, maximizing the robot's dynamic performance and payload-to-weight ratio.
Ready to start your build?
Our engineering team is ready to help you select the perfect robot joint modules for your application. Get expert advice and a custom quotation within 24 hours.
Get a Quote & DatasheetRelated articles you might find useful: